Robot Espacial
Build and control your explorer robot
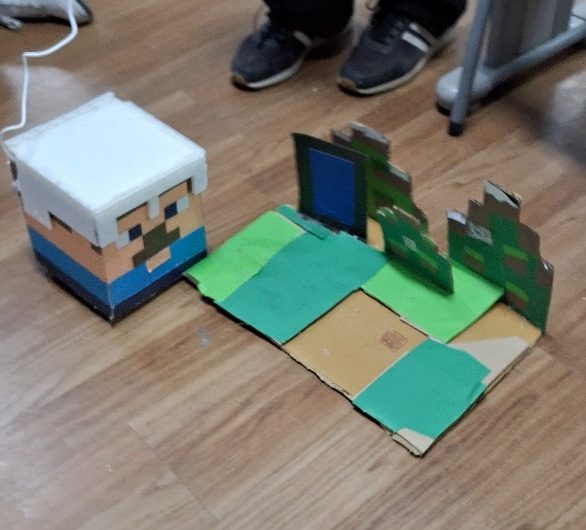
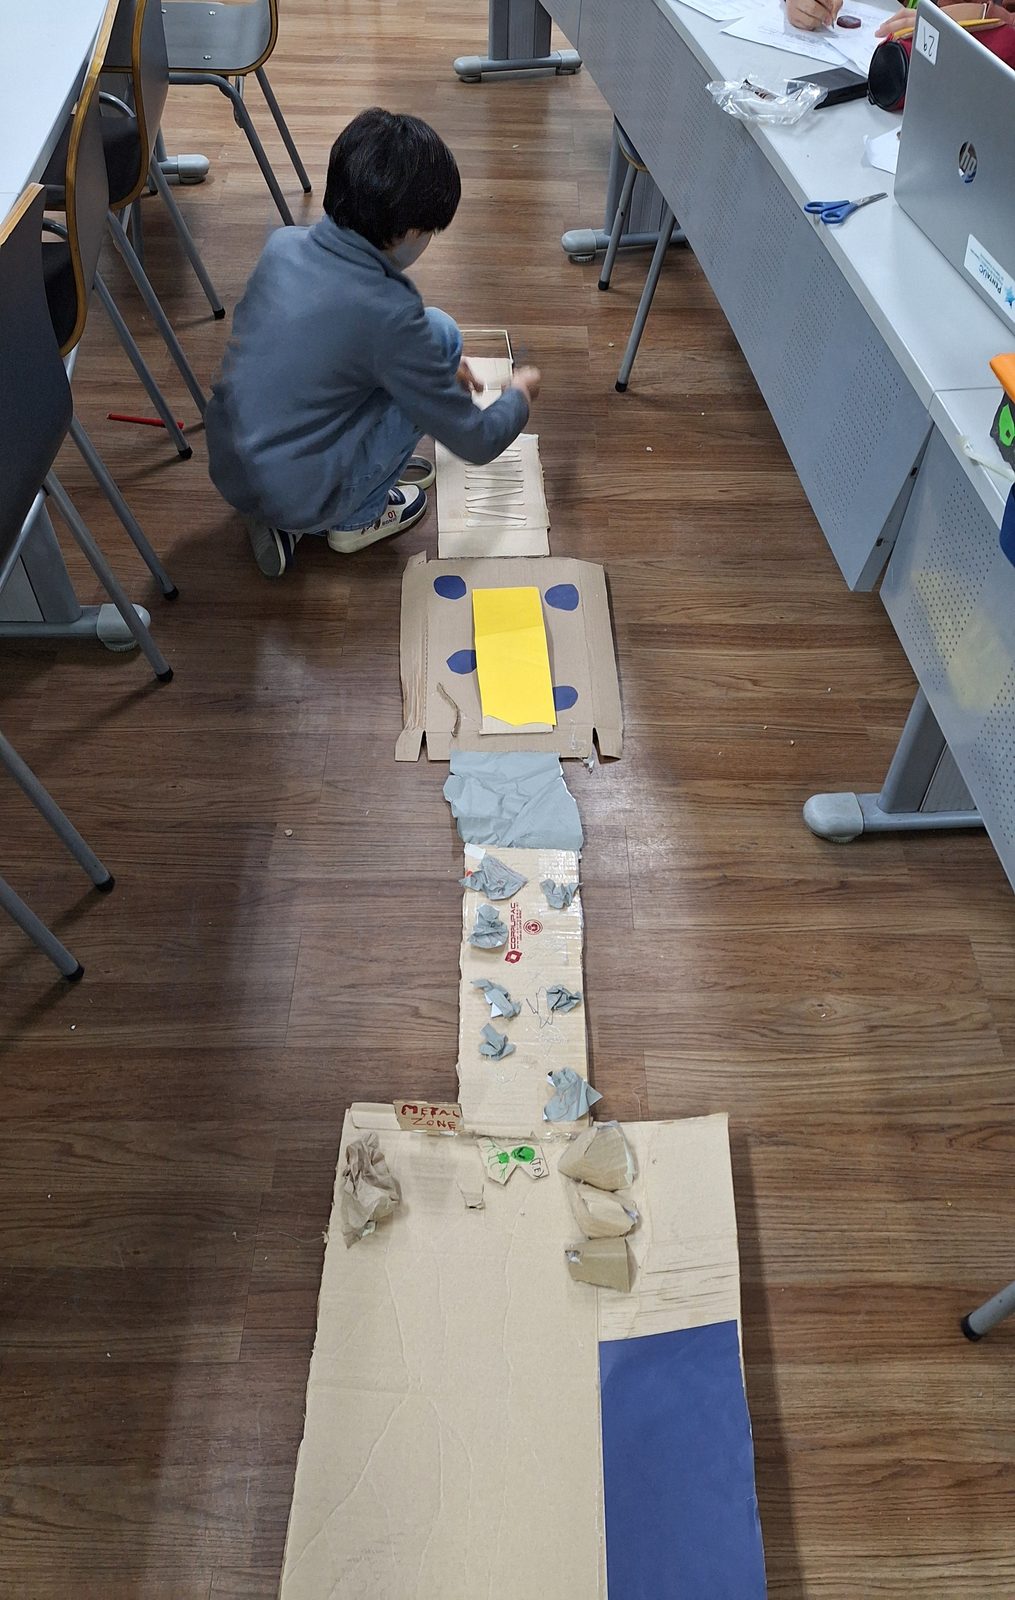
A full semester of space exploration: from the first circuit to a robot controlled remotely over Wi-Fi, with custom parts modeled in Tinkercad.
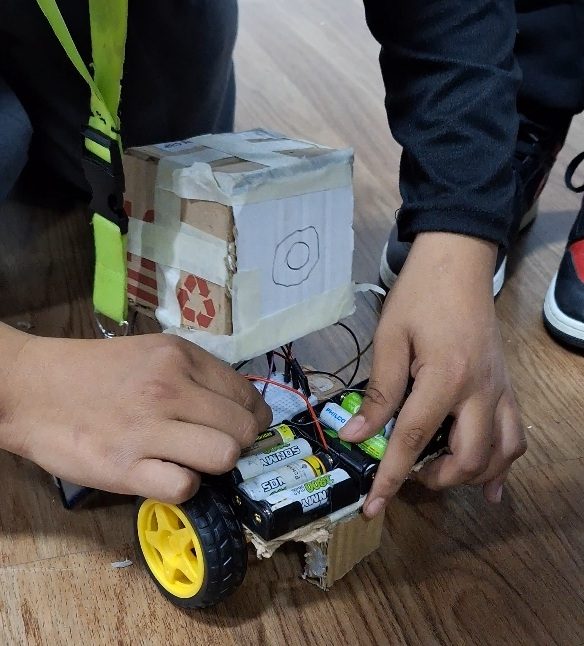
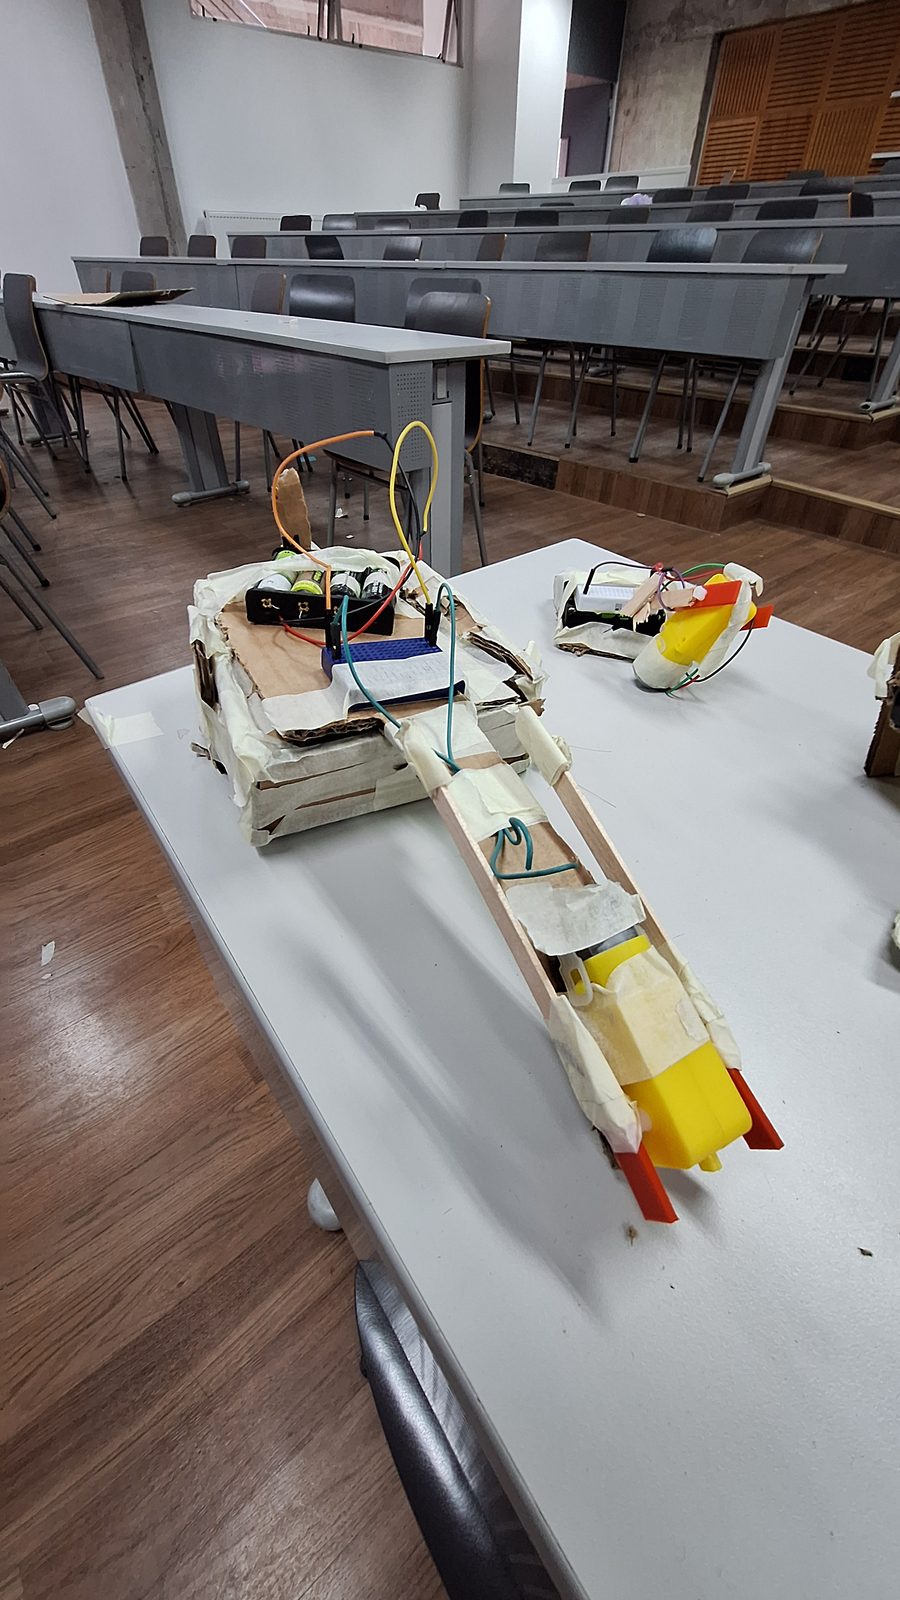
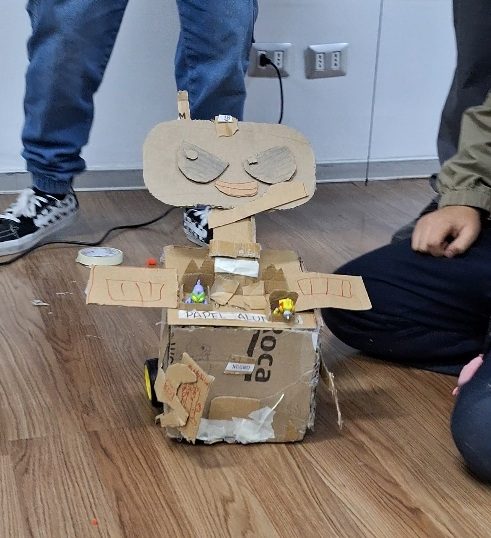
Robot Espacial takes the logic of the missions to a semester format, with more time to go deeper into each technical layer. Students start by understanding the real problems of space travel and end up with an explorer robot they program and control remotely over Wi-Fi.
The progression is deliberate: first the design methodology to approach complex problems, then electronics, then programming, and only then 3D modeling of the parts each robot needs. Each layer is assessed before the next one goes on.
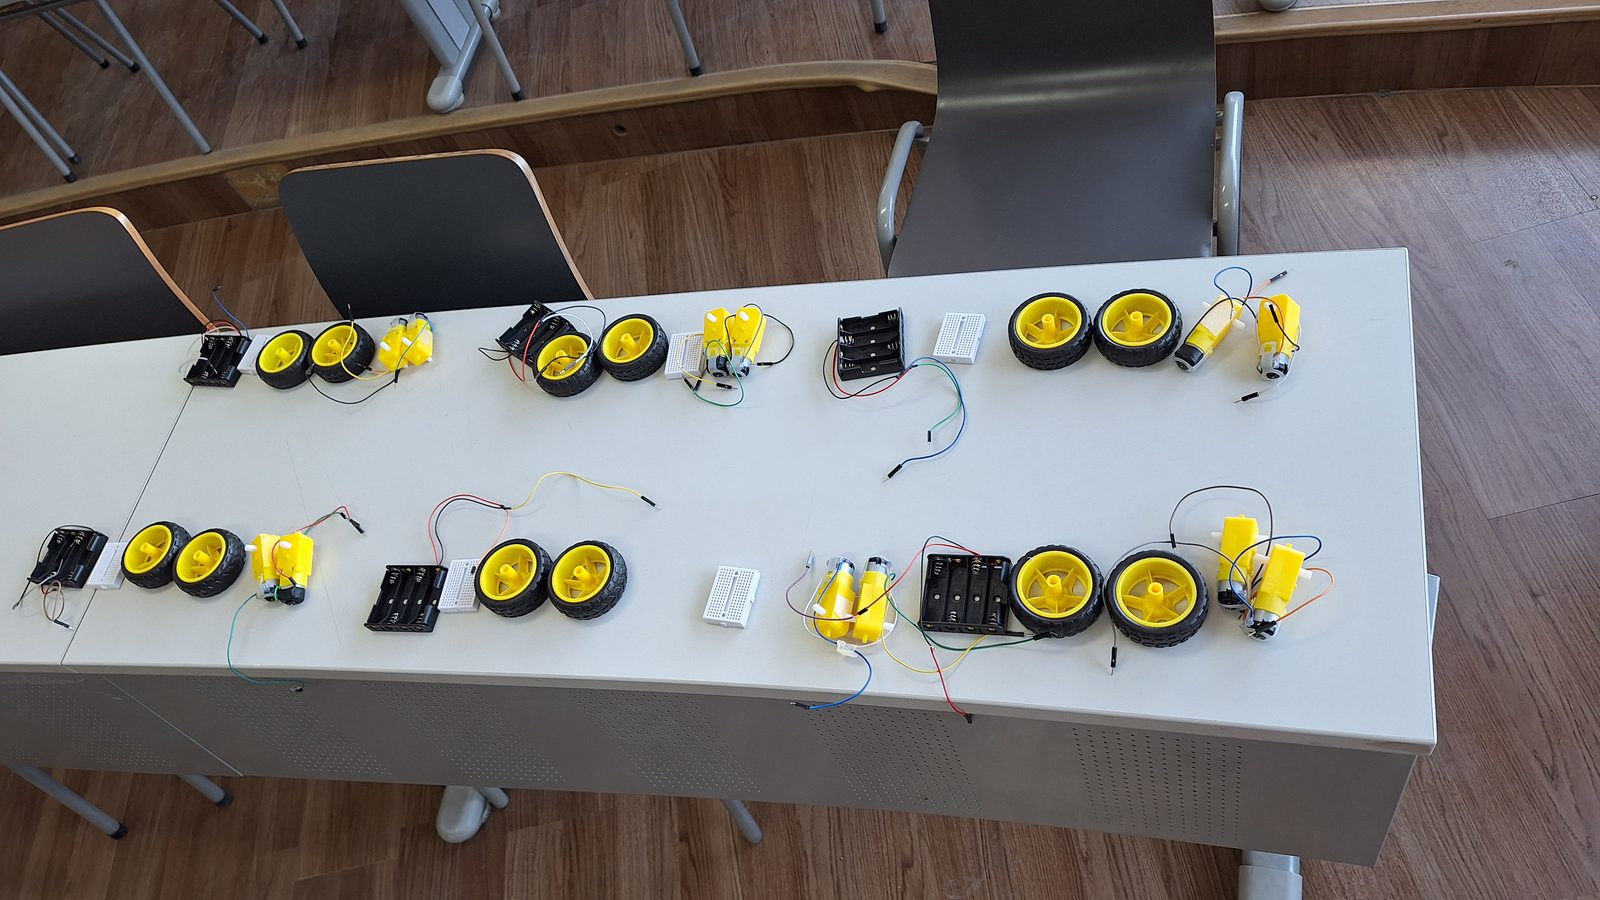
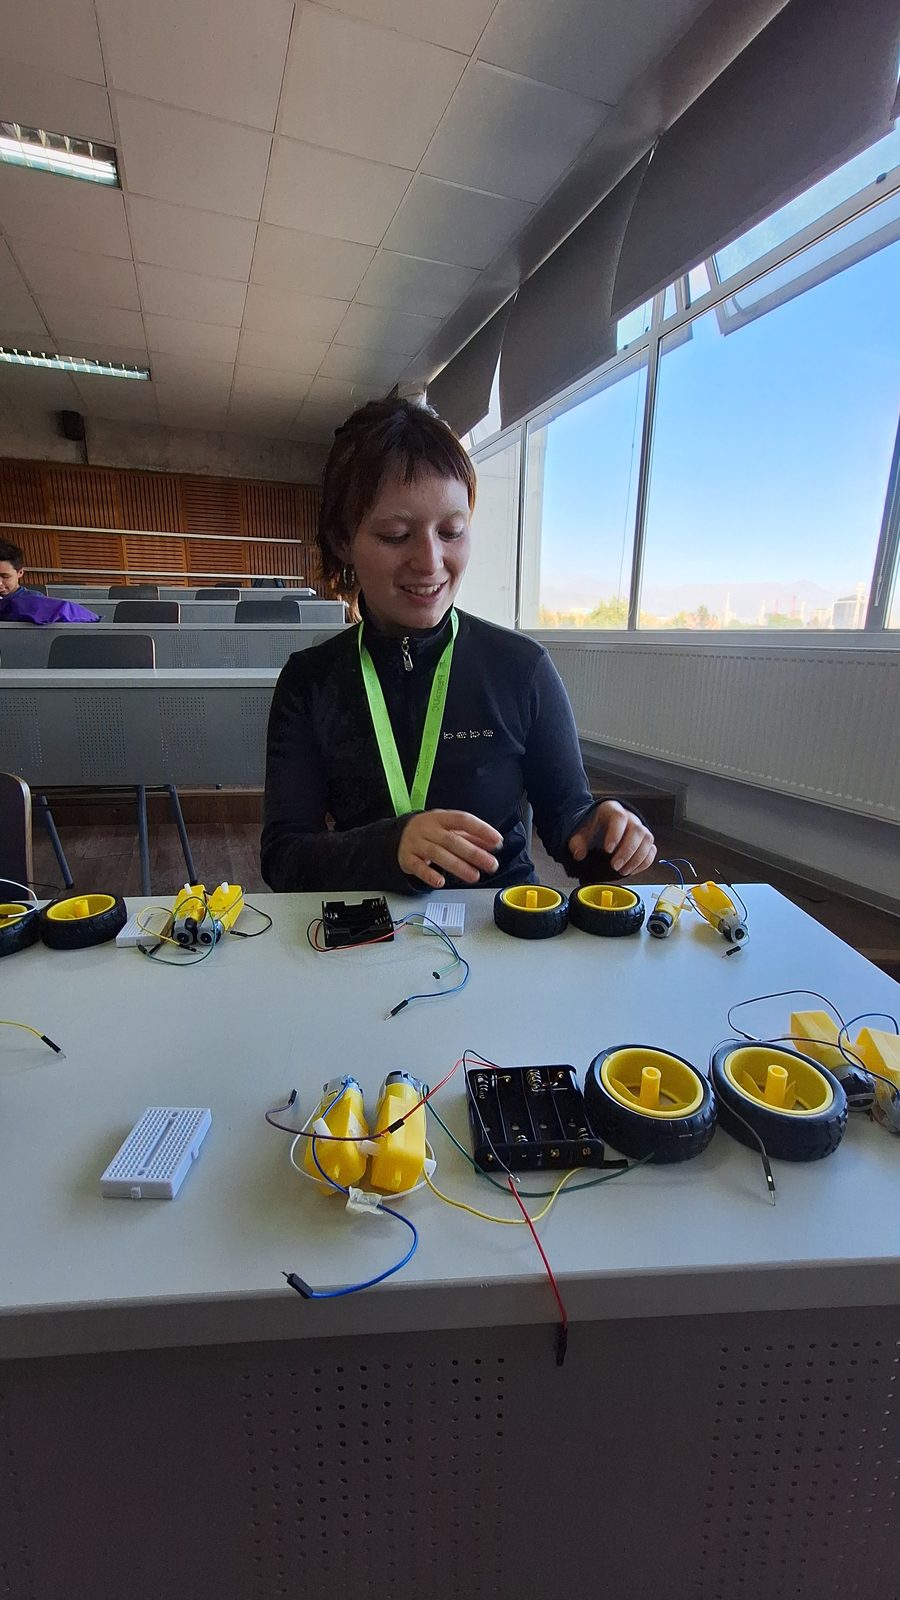
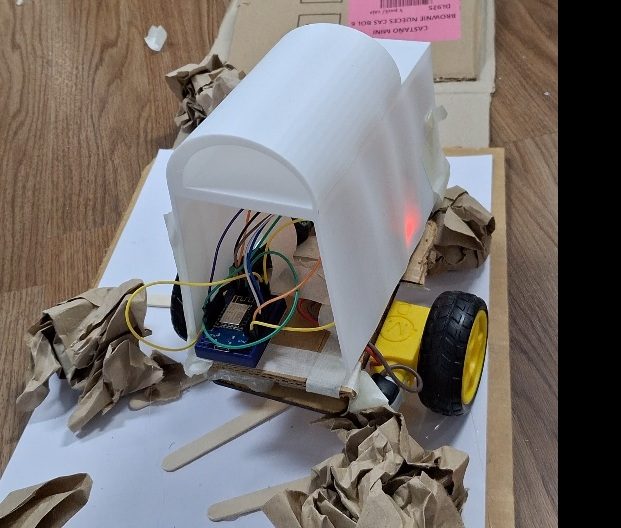
The course uses the same base educational robot, so class time goes into designing and solving instead of fighting with hardware that does not work.
Original course
Proposal, syllabus, methodology and materials designed by me.
About the educational robot
The third course built on the robot we created with Elvis Andrade for Robots Makers en Acción.
Syllabus
- 01Introduction to space explorationReal problems of space travel as a starting point.
- 02Design methodologyHow to approach complex problems through prototyping.
- 03Basic electronics fundamentalsCircuits, components and first connections.
- 04Introduction to programmingCode structure and control of the first movements.
- 05Preparing the midterm assessmentInstructions, rubric and team organization.
- 06Midterm assessmentProposals to address the problems of space travel.
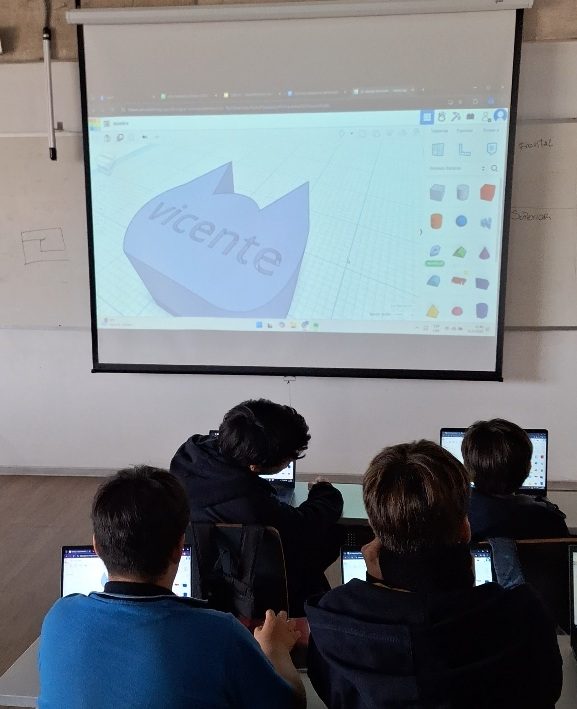
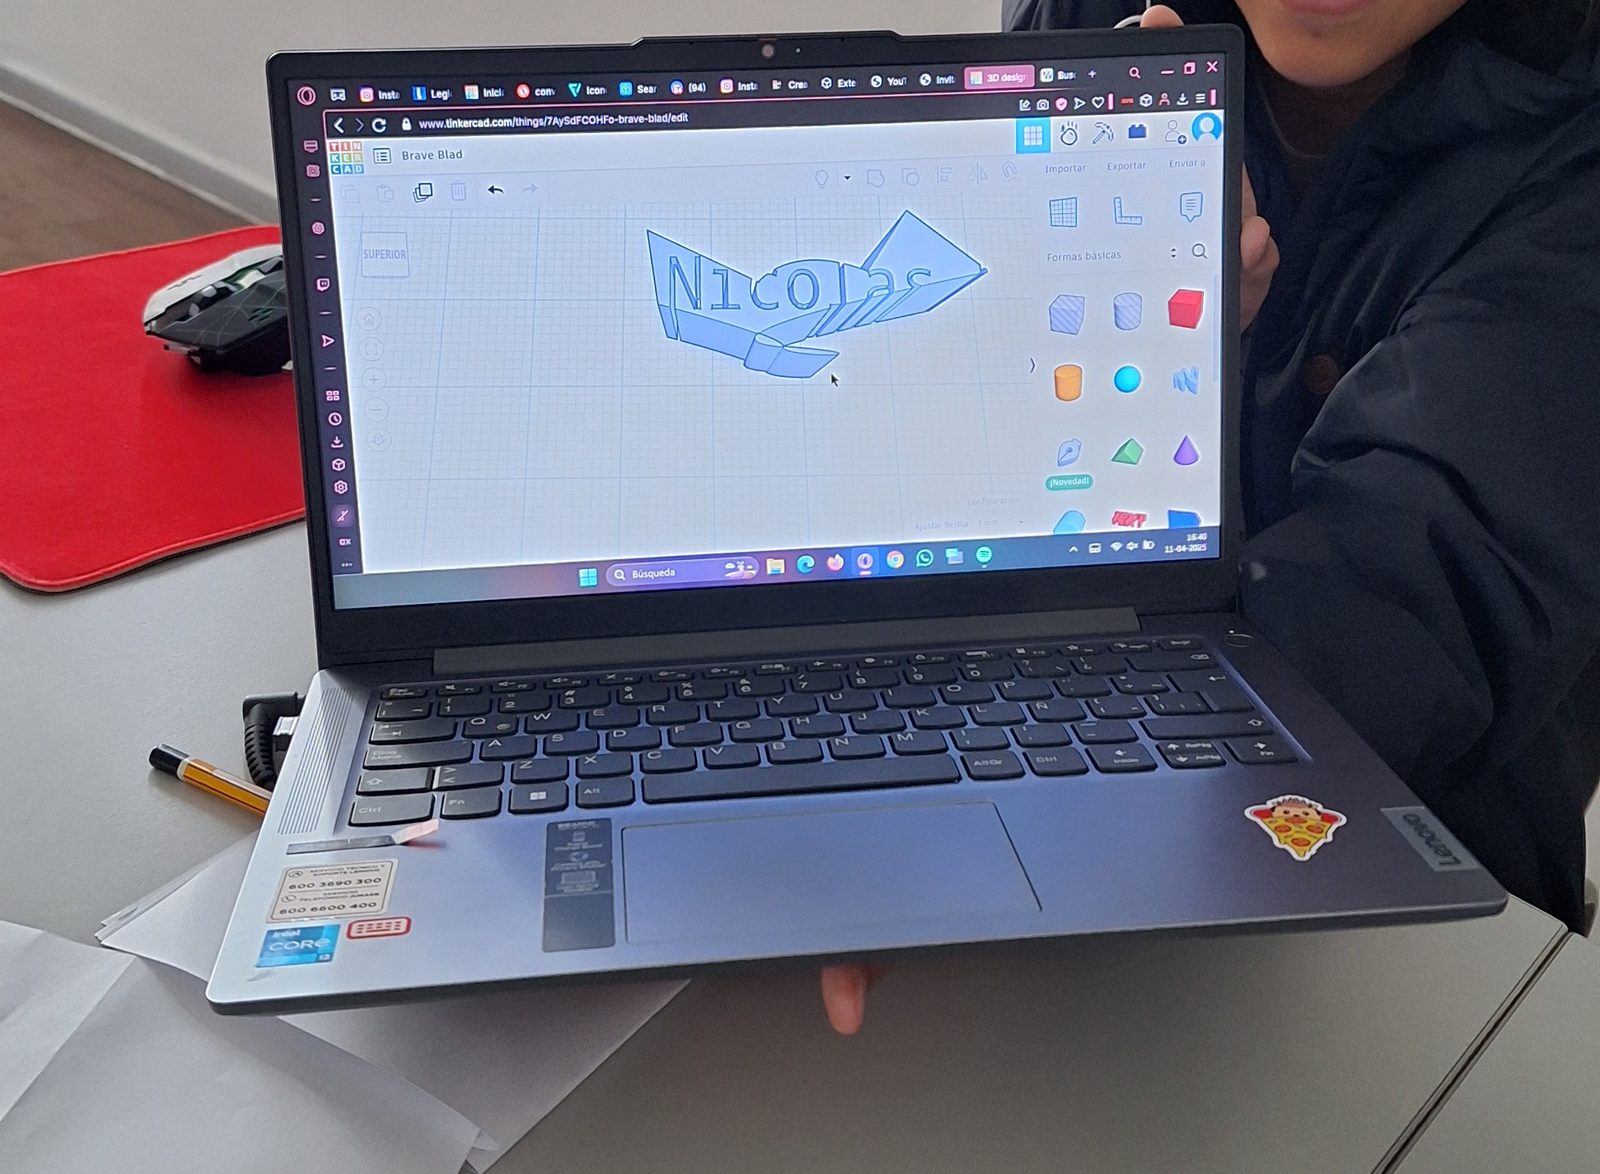
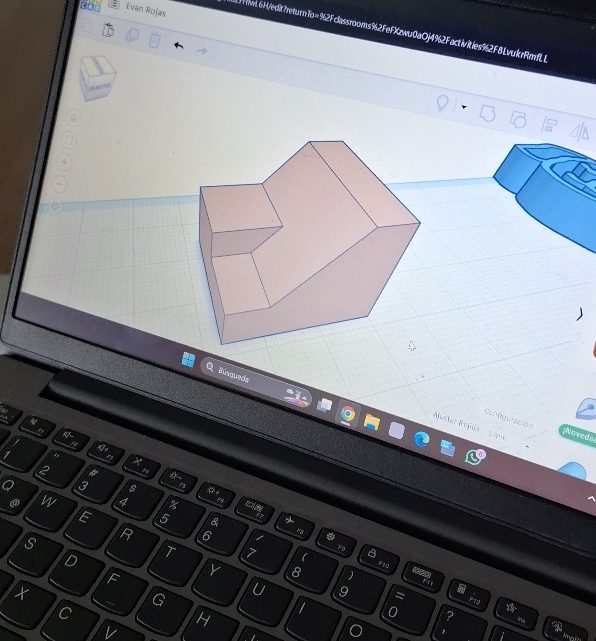
- 07Introduction to 3D modelingTinkercad applied to the parts each robot needs.
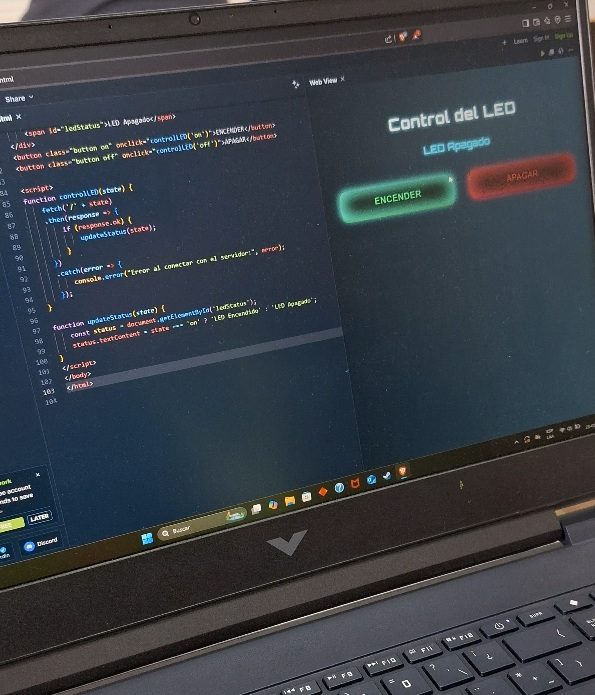
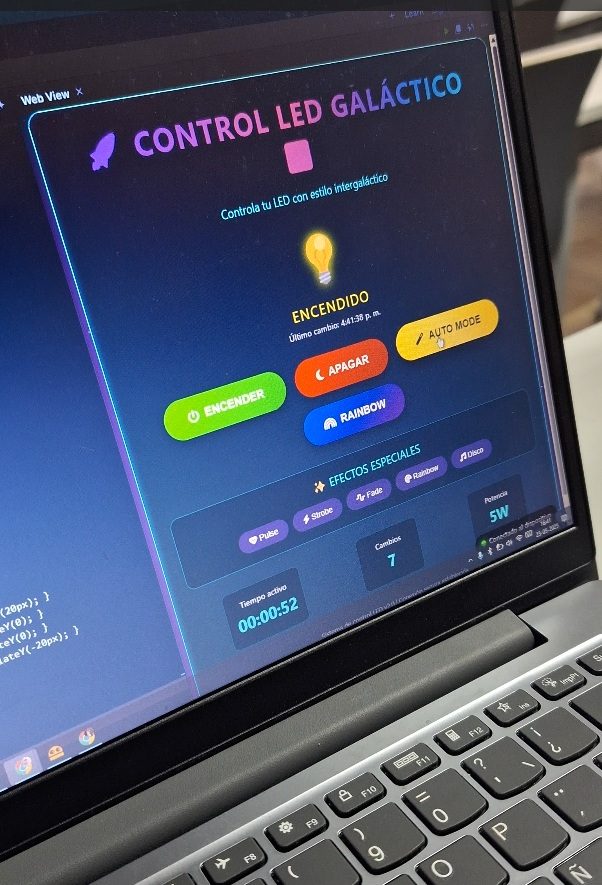
- 08Programming the robotMotor control and Wi-Fi communication.
- 09Final testing and fine-tuningTuning the robot's behavior on test runs.
- 10Preparing the final assessmentPresentation materials and rehearsal.
- 11Final assessment and learning fairShowcase of the finished robots.
- 12Final feedbackWrap-up and reflection on the semester's process.
Gallery